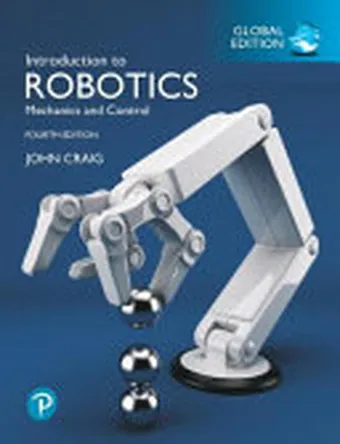
Introduction To Robotics Global Edition 4th cover

Introduction To Robotics Global Edition 4th

by John Craig

Price৳ 950
Price৳ 950

Have a question? Ask on WhatsApp or Message on Messenger

Call 01963 822422 / 01817 506044 for help with your order

Introduction to Robotics by John Craig is a foundational manual covering the mechanical, kinematic, and dynamic principles of robotic manipulator systems. Controlling physical robotic arms requires combining spatial geometry, rigid-body mechanics, and feedback control theory. Craig presents a systematic mathematical framework to analyze manipulator kinematics, calculate joint velocities, and design motion controllers.

What you will learn

  • Compute spatial descriptions and coordinate transformations with homogeneous matrices
  • Solve forward and inverse kinematics using Denavit-Hartenberg parameter conventions
  • Calculate manipulator Jacobians to map joint velocities to Cartesian end-effector motion
  • Derive equations of motion for multi-link manipulators using Lagrangian dynamics
  • Plan smooth trajectories in joint space and Cartesian workspace coordinates
  • Design linear and non-linear feedback controllers for precise trajectory tracking

Who this is for

Robotics engineers, mechanical and electrical engineering students, and software developers working on industrial automation. Working knowledge of linear algebra, basic calculus, and Newtonian mechanics is assumed. Prior robotics hardware experience is not required.